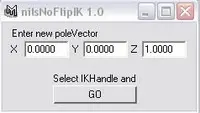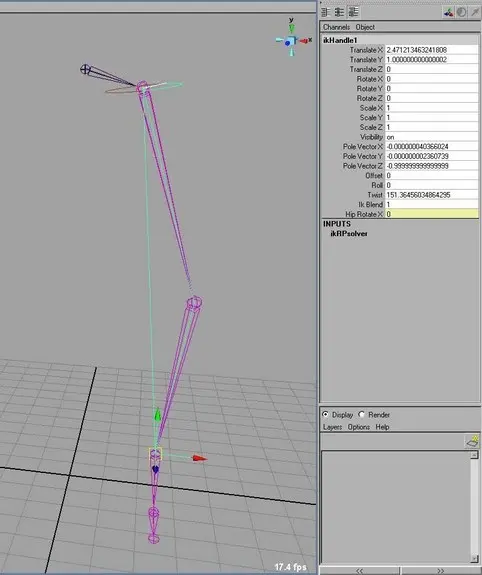
This script calculates the twist value on an ikHandle so that rotateX on the first joint in the ik chain equals 0.
When to use:
Let's say that you're creating a no-flip knee. You set the poleVector on the ikHandle to 0 0 -1 and then you must find a twist value so that rotateX on the hip-joint equals 0. If the leg is on a straight line, setting the twist value to 90 or -90 mostly gets the job done but what if the leg isn't on a straight line? Then you can either try and error the twist value all the way down to 15-decimals precision or you can run this script.
How to use:
Source, select ikHandle and run fixTwistIK(); in the commandline. That's it.
Limitations:
RotateX must be the twisting axis on the joint. 0 must be the desired value on rotateX. I'll fix this if there's a demand for it.
Please send any feedback to nils.lerin@gmail.com
Please use the Feature Requests to give me ideas.
Please use the Support Forum if you have any questions or problems.
Please rate and review in the Review section.